Industrial Robotics · Cobot Control
ABB Cobot Control
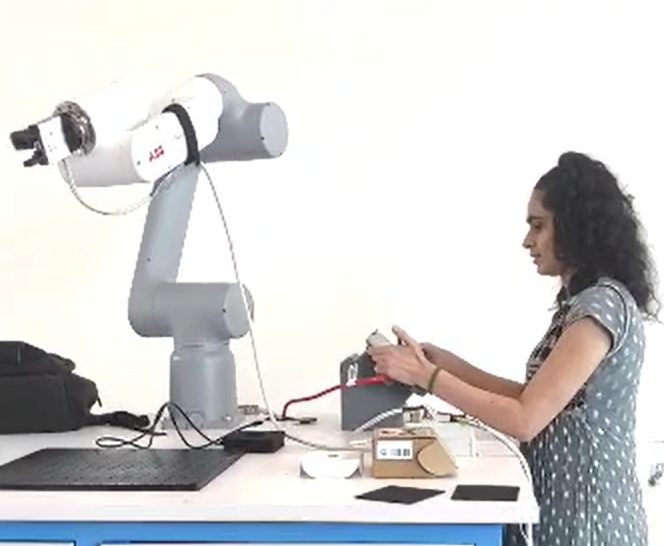
Getting hands-on time with an ABB collaborative robot arm — operating it directly via its controller, jogging the arm through target positions, and running through pick-and-place style routines on the physical hardware rather than just in simulation.
▸ operating the ABB cobot arm live — controller-driven movement, recorded on-site
What it is
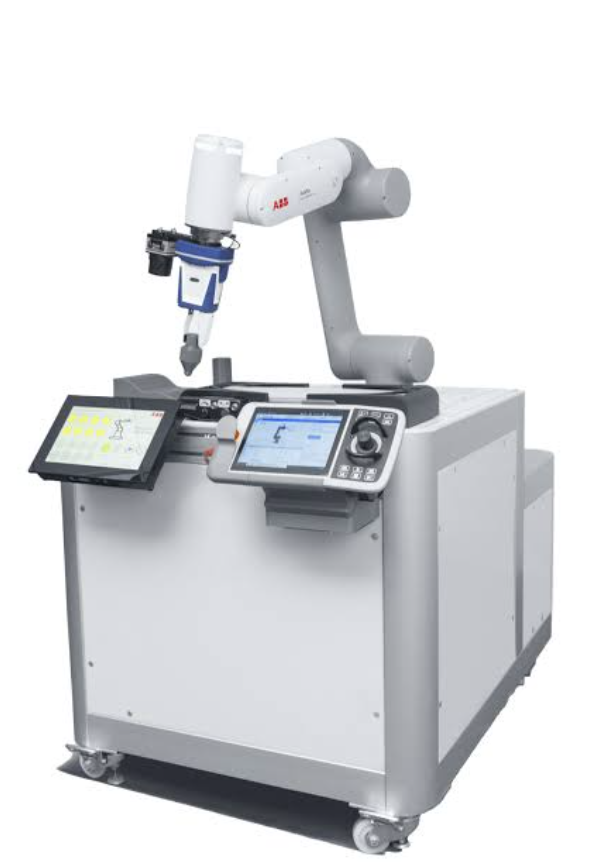
This project is hands-on operation of a real ABB collaborative robot (cobot) arm, mounted on its mobile controller base with a dual touchscreen and handheld teach pendant. Rather than working purely in simulation, the goal was to actually jog the arm through space, teach it specific waypoints, and understand how an industrial controller thinks about motion, safety, and I/O — the same skills used on real manufacturing floors.
How it works
Power up & connect
The cobot's mobile base unit is powered on, and the handheld teach pendant is connected to establish manual control over the arm.
Manual jogging
Using the pendant, each joint (and the tool center point in Cartesian mode) is jogged to get a feel for the arm's reach and range of motion.
Teaching waypoints
Target positions are taught directly on the physical arm and saved as waypoints, which the controller can then string together into a motion sequence.
Running the routine
The taught sequence is run back through the controller, driving the cobot through a repeatable pick-and-place style path — with the dual touchscreen managing program flow and safety.